Bayesian Model Predictive Control for Quantum State Regulation under Decoherence
Thanana Nuchkrua
To be presented at IFAC World Congress 2026, Busan, Korea,
August 24–28, 2026.
-
Highlights
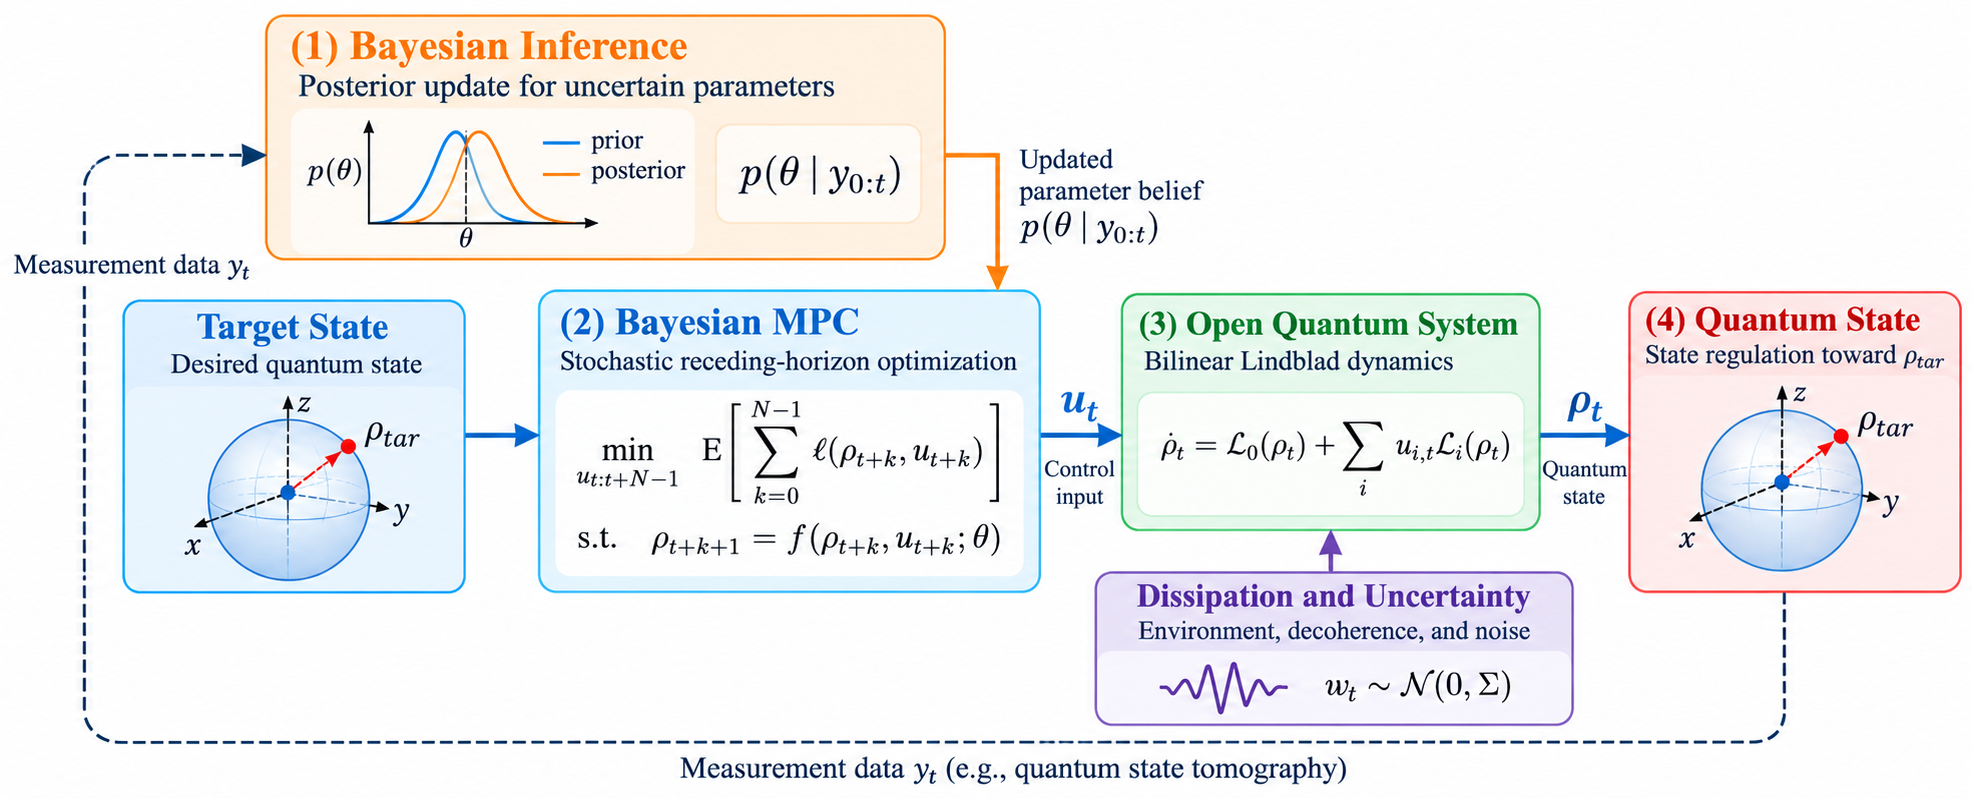
Bayesian MPC closed-loop pipeline: posterior updating, stochastic receding-horizon optimization, and constrained control applied to Lindblad quantum dynamics.
-
Code: Implemented in Julia
using RK4 integration, adjoint-gradient MPC, and Bayesian EKF for online parameter learning.
Abstract. We develop a Bayesian Model Predictive Control (BMPC) framework for adaptive quantum state regulation under model uncertainty. The method embeds Bayesian parameter inference directly into the receding-horizon optimization, enabling the controller to update uncertain Hamiltonian parameters online while computing constrained control inputs in real time. We formulate the BMPC architecture for Lindblad open-system dynamics and establish theoretical guarantees showing that posterior contraction drives the BMPC law toward the nominal MPC law, recovering its stability properties. Numerical experiments on single-qubit state-transfer tasks demonstrate that BMPC preserves high fidelity under parameter drift, decoherence, and measurement noise, and that short prediction horizons are sufficient for real-time feasibility — making BMPC a principled and practical strategy for quantum feedback control under uncertainty.
Key Results
Closed-system drift: BMPC achieves terminal fidelity \(\mathcal{F}\approx1.0\) under 10% Hamiltonian drift mismatch, outperforming both open-loop GRAPE and nominal MPC.
Decoherence robustness: Under amplitude-damping at rates \(\gamma\in\{0.05,0.1,0.2\}\), BMPC consistently maintains higher fidelity and approaches the theoretical bound \(\mathcal{F}_{\mathrm{ref}}=\exp(-\gamma\tau_\pi/2)\).
Measurement noise: Over 50 Monte Carlo trials with readout error \(p_{\mathrm{meas}}\in[0,0.2]\), BMPC degrades significantly more slowly than GRAPE and nominal MPC, owing to Bayesian filtering of measurement uncertainty.
Real-time feasibility: Terminal fidelity plateaus beyond \(N_p\approx16\) while runtime grows linearly — confirming that short horizons are sufficient for near-term quantum hardware.
Theoretical Contributions
Lemma (Posterior contraction): \(\mathbb{E}[\|\Phi(\rho,u;\theta)-\Phi(\rho,u;\theta^\star)\|_F] \leq L_\theta\,\varepsilon_t \to 0\) as the posterior concentrates at \(\theta^\star\).
Theorem (Nominal limit): \(\|u_t^{\mathrm{BMPC}}-u_t^{\mathrm{NMPC}}\|_2 \leq \sqrt{2K_\theta/\sigma_{\min}}\,\varepsilon_t^{1/2} \to 0\). BMPC asymptotically inherits the stability of nominal MPC.
Proposition (ISS under decoherence): \(1-\mathcal{F}(\rho_t,\rho_\star) \leq \mu^t e_0 + (L_f/\alpha_3)\|\mathcal{D}_\theta\|_\infty\). Practical fidelity stability with explicit decoherence bound.